Gaotian Wang

Gaotian Wang

Ph.D. Candidate at Rice University · Prev. Intern at NVIDIA

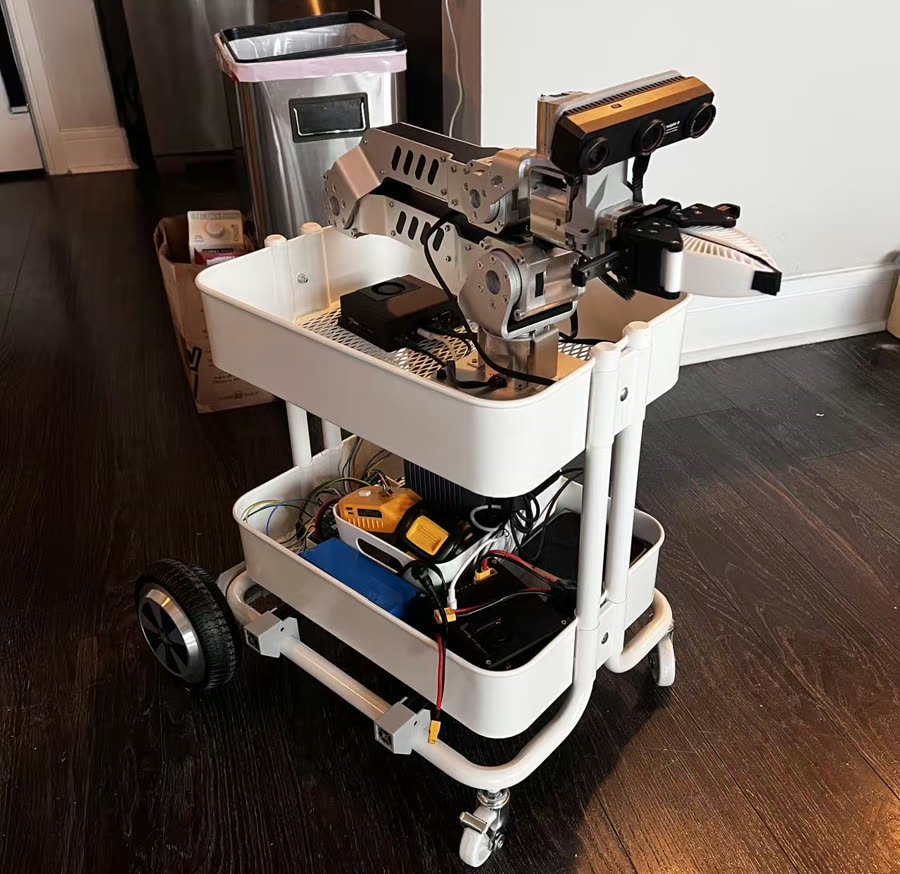
I am a fifth-year Ph.D. student at Rice University, advised by Kaiyu Hang in the RobotΠ Lab. Previously, I was a research intern at the NVIDIA Seattle Robotics Lab (May–Aug. 2026), and I created XLeRobot, an open-source $660 dual-arm mobile robot (5.5k+ GitHub stars).

My research focuses on robust and dexterous manipulation in the real world:

  • Manipulation under uncertainty: virtual temporal cages and funnels that bound object motion over time (IJRR)
  • World models & sim-to-real: physics-aware world models and zero-shot sim-to-real RL (IROS 2026, RSS 2026)
  • Learning from human video: data engines that lift in-the-wild videos into robot actions (EgoInfinity)
  • Agentic robotics: deploying and self-improving policies on real robots, from mobile manipulators to humanoids

News

Projects

Publications

RoboTok: A Scalable Data Engine for Internet Demonstration Video Retrieval and Dexterous Manipulation Learning

Howard Qian, Yiting Chen, Yunfei Xie, Kejia Ren, Podshara Chanrungmaneekul, Gaotian Wang, Bowen Wen, Chen Wei, Kaiyu Hang
arXiv 2026arXiv preprint
PDF Project Code Data
Robot learning increasingly depends on broad and diverse demonstrations, yet collecting robot data remains expensive and difficult to scale across the wide range of real-world tasks. To address this bottleneck, we introduce RoboTok, a scalable data engine that uses a query human manipulation video to retrieve manipulation-relevant internet demonstrations for training dexterous robot policies. Specifically, we learn a latent motion space from 3D hand trajectories expressed in estimated actor-centered reference frames. This representation enables manipulation behaviors to be compared across variations in camera viewpoint, scene appearance, and actor occlusions, while remaining compact enough for efficient indexing and retrieval over internet video collections. We evaluate RoboTok against existing robot-data retrieval approaches using retrieval metrics and downstream robot policy performance, showing that RoboTok retrieves more manipulation-relevant demonstrations and improves downstream task success. In real-world robot experiments, RoboTok-guided policies achieve a mean success improvement of 42.2 percentage points over the strongest baseline for each task, establishing hand-pose trajectory-aware retrieval as a scalable way to leverage continuously growing web video for robot learning.
@article{qian2026robotok,
  title   = {{RoboTok}: A Scalable Data Engine for Internet Demonstration Video Retrieval and Dexterous Manipulation Learning},
  author  = {Qian, Howard and Chen, Yiting and Xie, Yunfei and Ren, Kejia and Chanrungmaneekul, Podshara and Wang, Gaotian and Wen, Bowen and Wei, Chen and Hang, Kaiyu},
  journal = {arXiv preprint arXiv:2609.03199},
  year    = {2026}
}',
 

EgoInfinity: A Web-Scale 4D Hand-Object Interaction Data Engine for Any-View Robot Retargeting and Video-to-Action Robot Learning

Gaotian Wang, Kejia Ren, Andrew S. Morgan, Yiting Chen, Howard H. Qian, Podshara Chanrungmaneekul, Kaiyu Hang
arXiv 2026arXiv preprint
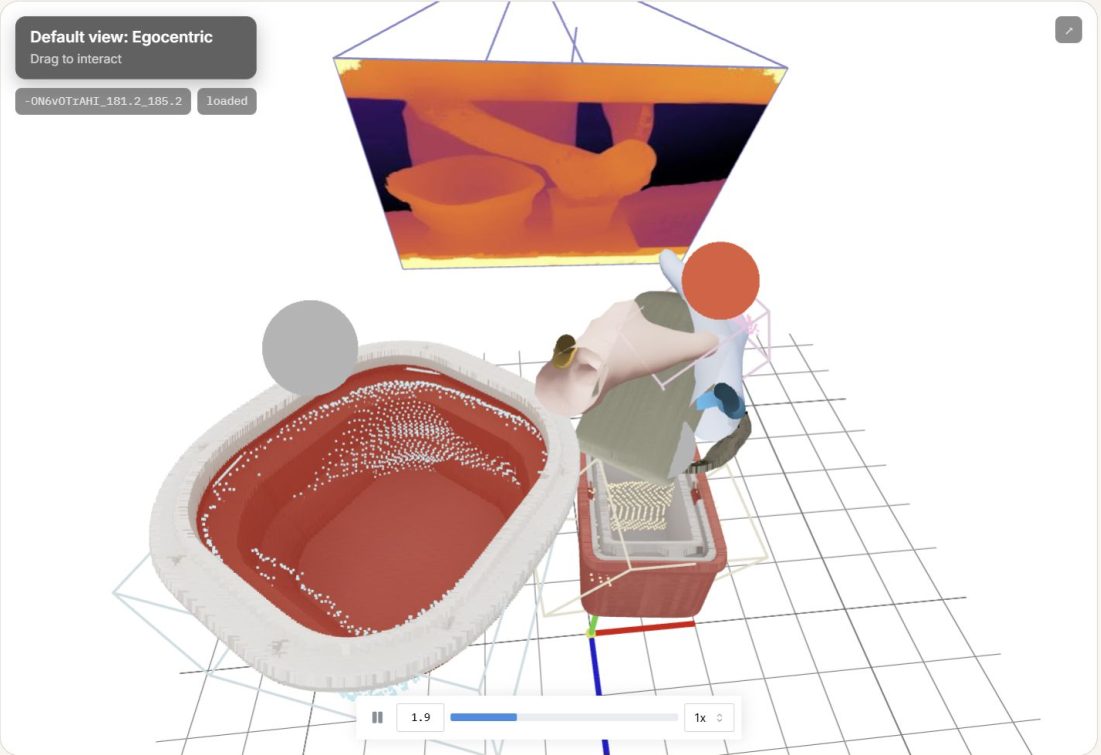
Internet videos constitute the largest reservoir of embodied human manipulation knowledge, yet converting arbitrary RGB footage into actionable robot training data remains a major bottleneck. Existing lab- or factory-collected datasets are narrow in scale and diversity, limiting open-world robot learning. Instead of proposing a static dataset, we introduce EgoInfinity, a universal 4D hand-object interaction data engine that enables web-scale data generation for robot retargeting and learning. EgoInfinity is a modular engine integrating perception, segmentation, reconstruction, interaction-aware refinement, and retargeting to automate this traditionally unscalable video-to-action problem without human-in-the-loop annotation. Its modular design lets the engine continuously benefit from advances in any incorporated component. With EgoInfinity, in-the-wild human manipulation videos are lifted into agent-agnostic, metric 4D hand-object representations, including hand trajectories, 6-DoF object poses, and contact-relevant states. Rather than naively connecting standalone components, EgoInfinity combines cross-module metric calibration with interaction-aware refinement to improve physical reliability, reducing drift and contact inconsistencies common in pure visual reconstruction. We further propose a novel motion retargeter that compiles the recovered 3D hand motions into executable joint trajectories for diverse robot morphologies, enabling video-to-action retargeting on any robot from arbitrary viewpoints and shot sizes (e.g., the human body is only partially visible). We validate EgoInfinity across perception fidelity, kinematic feasibility, contact consistency, cross-embodiment generalization, and real-robot skill acquisition (e.g., grasping, cutting, wiping, and pouring), demonstrating a scalable bridge from internet videos to executable robot behavior for open-world robot learning.
@misc{wang_egoinfinity_2026,
    title = {{EgoInfinity}: A Web-Scale 4D Hand-Object Interaction Data Engine for Any-View Robot Retargeting and Video-to-Action Robot Learning},
    author = {Wang, Gaotian and Ren, Kejia and Morgan, Andrew S. and Chen, Yiting and Qian, Howard H. and Chanrungmaneekul, Podshara and Hang, Kaiyu},
    year = {2026},
    eprint = {2606.17385},
    archivePrefix = {arXiv},
    primaryClass = {cs.RO},
    url = {https://arxiv.org/abs/2606.17385}
}

ManiDreams: An Open-Source Library for Robust Object Manipulation via Uncertainty-aware Task-specific Intuitive Physics

Gaotian Wang, Kejia Ren, Andrew S. Morgan, Kaiyu Hang
IROS 2026IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
@inproceedings{wang_manidreams_2026,
    title = {{ManiDreams}: An Open-Source Library for Robust Object Manipulation via Uncertainty-aware Task-specific Intuitive Physics},
    author = {Wang, Gaotian and Ren, Kejia and Morgan, Andrew S. and Hang, Kaiyu},
    booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
    year = {2026}
}

Zero-Shot Sim-to-Real Robot Learning: A Dexterous Manipulation Study on Reactive Catching

Kejia Ren, Gaotian Wang, Andrew S. Morgan, Kaiyu Hang
RSS 2026Robotics: Science and Systems (RSS)
PDF Video
Dexterous manipulation is physics-intensive and highly sensitive to modeling errors and perception noise, making sim-to-real transfer prohibitively challenging. Domain randomization (DR) is commonly used to improve the robustness of learned policies for such tasks, but conventional DR randomizes one instance per episode, offering very limited exposure to the variability of real-world dynamics. To this end, we propose Domain-Randomized Instance Set (DRIS), which represents and propagates a set of randomized instances simultaneously, providing richer approximation of uncertain dynamics and enabling policies to learn actions that account for multiple possible outcomes. Supported by theoretical analysis, we show that DRIS yields more robust policies and alleviates the need for real-world fine-tuning, even with a modest number of instances (e.g., 10). We demonstrate this on a challenging reactive catching task. Unlike traditional catching setups that use end-effectors designed to mechanically stabilize the object (e.g., curved or enclosing surfaces), our system uses a flat plate that offers no passive stabilization, making the task highly sensitive to noise and requiring rapid reactive motions. The learned policies exhibit strong robustness to uncertainties and achieve reliable zero-shot sim-to-real transfer.
@inproceedings{ren_catch_2026,
    title = {Zero-Shot Sim-to-Real Robot Learning: A Dexterous Manipulation Study on Reactive Catching},
    author = {Ren, Kejia and Wang, Gaotian and Morgan, Andrew S. and Hang, Kaiyu},
    booktitle = {Robotics: Science and Systems (RSS)},
    year = {2026}
}

Caging in Dreams: Zero-shot Object Manipulation via Diffusion-based Task-Specific Intuitive Physics and In-Representation Domain Randomization

Gaotian Wang, Kejia Ren, Andrew S. Morgan, Kaiyu Hang
Under review

Caging in Time: A Framework for Robust Object Manipulation under Uncertainties and Limited Robot Perception

Gaotian Wang, Kejia Ren, Andrew S. Morgan, Kaiyu Hang
IJRR 2025International Journal of Robotics Research (IJRR)
PDF 中文 Poster Video
Real-world object manipulation has been commonly challenged by physical uncertainties and perception limitations. Being an effective strategy, while caging configuration-based manipulation frameworks have successfully provided robust solutions, they are not broadly applicable due to their strict requirements on the availability of multiple robots, widely distributed contacts, or specific geometries of the robots or the objects. To this end, this work proposes a novel concept, termed Caging in Time, to allow caging configurations to be formed even if there is just one robot engaged in a task. This novel concept can be explained by an insight that even if a caging configuration is needed to constrain the motion of an object, only a small portion of the cage is actively manipulating at a time. As such, we can switch the configuration of the robot strategically so that by collapsing its configuration in time, we will see a cage formed and its necessary portion active whenever needed. We instantiate our Caging in Time theory on challenging quasistatic and dynamic manipulation tasks, showing that Caging in Time can be achieved in general state spaces including geometry-based and energy-based spaces. With extensive experiments, we show robust and accurate manipulation, in an open-loop manner, without requiring detailed knowledge of the object geometry or physical properties, nor realtime accurate feedback on the manipulation states. In addition to being an effective and robust open-loop manipulation solution, the proposed theory can be a supplementary strategy to other manipulation systems affected by uncertain or limited robot perception.
@article{wang2025caging,
    title={Caging in Time: A Framework for Robust Object Manipulation under Uncertainties and Limited Robot Perception},
    author={Wang, Gaotian and Ren, Kejia and Morgan, Andrew S. and Hang, Kaiyu},
    journal={The International Journal of Robotics Research (IJRR)},
    year={2025}
    }

Object-Centric Kinodynamic Planning for Nonprehensile Robot Rearrangement Manipulation

Kejia Ren, Gaotian Wang, Andrew S. Morgan, Lydia E. Kavraki, Kaiyu Hang
T-RO 2025The IEEE Transactions on Robotics (T-RO)
PDF Publisher Video
Nonprehensile actions such as pushing are crucial for addressing multi-object rearrangement problems. To date, existing nonprehensile solutions are all robot-centric, i.e., the manipulation actions are generated with robot-relevant intent and their outcomes are passively evaluated afterwards. Such pipelines are very different from human strategies and are typically inefficient. To this end, this work proposes a novel object-centric planning paradigm and develops the first object-centric planner for general nonprehensile rearrangement problems. By assuming that each object can actively move without being driven by robot interactions, the object-centric planner focuses on planning desired object motions, which are realized via robot actions generated online via a closed-loop pushing strategy. Through extensive experiments and in comparison with state-of-the-art baselines in both simulation and on a physical robot, we show that our object-centric paradigm can generate more intuitive and task-effective robot actions with significantly improved efficiency. In addition, we propose a benchmarking protocol to standardize and facilitate future research in nonprehensile rearrangement.
@article{ren2025objectcentric,
    title={Object-Centric Kinodynamic Planning for Nonprehensile Robot Rearrangement Manipulation},
    author={Ren, Kejia and Wang, Gaotian and Morgan, Andrew S. and Kavraki, Lydia E. and Hang, Kaiyu},
    journal={IEEE Transactions on Robotics (T-RO)},
    year={2025},
    url={https://ieeexplore.ieee.org/document/11176447}
    }

Collision-inclusive Manipulation Planning for Occluded Object Grasping via Compliant Robot Motions

Kejia Ren, Gaotian Wang, Andrew S. Morgan, Kaiyu Hang
RA-L 2025IEEE Robotics and Automation Letters (RAL)
PDF Video
Traditional robotic manipulation mostly focuses on collision-free tasks. In practice, however, many manipulation tasks (e.g., occluded object grasping) require the robot to intentionally collide with the environment to reach a desired task configuration. By enabling compliant robot motions, collisions between the robot and the environment are allowed and can thus be exploited, but more physical uncertainties are introduced. To address collision-rich problems such as occluded object grasping while handling the involved uncertainties, we propose a collision-inclusive planning framework that can transition the robot to a desired task configuration via roughly modeled collisions absorbed by Cartesian impedance control. By strategically exploiting the environmental constraints and exploring inside a manipulation funnel formed by task repetitions, our framework can effectively reduce physical and perception uncertainties. With real-world evaluations on both single-arm and dual-arm setups, we show that our framework is able to efficiently address various realistic occluded grasping problems where a feasible grasp does not initially exist.
@article{ren2025collision,
    title={Collision-inclusive Manipulation Planning for Occluded Object Grasping via Compliant Robot Motions},
    author={Ren, Kejia and Wang, Gaotian and Morgan, Andrew S. and Hang, Kaiyu},
    journal={IEEE Robotics and Automation Letters (RAL)},
    year={2025},
    url={https://arxiv.org/abs/2412.06983}
    }

rt-RISeg: Real-Time Model-Free Robot Interactive Segmentation for Active Instance-Level Object Understanding

Howard H. Qian, Yiting Chen, Gaotian Wang, Podshara Chanrungmaneekul, Kaiyu Hang
IROS 2025IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
PDF Video
Successful execution of dexterous robotic manipulation tasks in new environments, such as grasping, depends on the ability to proficiently segment unseen objects from the background and other objects. Previous works in unseen object instance segmentation (UOIS) train models on large-scale datasets, which often leads to overfitting on static visual features. This dependency results in poor generalization performance when confronted with out-of-distribution scenarios. To address this limitation, we rethink the task of UOIS based on the principle that vision is inherently interactive and occurs over time. We propose a novel real-time interactive perception framework, rt-RISeg, that continuously segments unseen objects by robot interactions and analysis of a designed body frame-invariant feature (BFIF). We demonstrate that the relative rotational and linear velocities of randomly sampled body frames, resulting from selected robot interactions, can be used to identify objects without any learned segmentation model. This fully self-contained segmentation pipeline generates and updates object segmentation masks throughout each robot interaction without the need to wait for an action to finish. We showcase the effectiveness of our proposed interactive perception method by achieving an average object segmentation accuracy rate 27.5% greater than state-of-the-art UOIS methods. Furthermore, although rt-RISeg is a standalone framework, we show that the autonomously generated segmentation masks can be used as prompts to vision foundation models for significantly improved performance.
@inproceedings{qian_rtriseg_2025,
    title = {rt-{RISeg}: Real-Time Model-Free Robot Interactive Segmentation for Active Instance-Level Object Understanding},
    author = {Qian, Howard H. and Chen, Yiting and Wang, Gaotian and Chanrungmaneekul, Podshara and Hang, Kaiyu},
    booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
    year = {2025}
}

UNO Push: Unified Nonprehensile Object Pushing via Non-Parametric Estimation and Model Predictive Control

Gaotian Wang, Kejia Ren, Kaiyu Hang
IROS 2024IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
PDF Video
Nonprehensile manipulation through precise pushing is an essential skill that has been commonly challenged by perception and physical uncertainties, such as those associated with contacts, object geometries, and physical properties. For this, we propose a unified framework that jointly addresses system modeling, action generation, and control. While most existing approaches either heavily rely on a priori system information for analytic modeling, or leverage a large dataset to learn dynamic models, our framework approximates a system transition function via non-parametric learning only using a small number of exploratory actions (ca. 10). The approximated function is then integrated with model predictive control to provide precise pushing manipulation. Furthermore, we show that the approximated system transition functions can be robustly transferred across novel objects while being online updated to continuously improve the manipulation accuracy. Through extensive experiments on a real robot platform with a set of novel objects and comparing against a state-of-the-art baseline, we show that the proposed unified framework is a light-weight and highly effective approach to enable precise pushing manipulation all by itself. Our evaluation results illustrate that the system can robustly ensure millimeter-level precision and can straightforwardly work on any novel object.
@misc{wang_push_2024,
    title = {{UNO} Push: Unified Nonprehensile Object Pushing via Non-Parametric Estimation and Model Predictive Control},
    url = {http://arxiv.org/abs/2403.13274},
    author = {Wang, Gaotian and Ren, Kejia and Hang, Kaiyu},
    date = {2024-03-19},
    eprint = {2403.13274 [cs]},
    publisher = {arXiv},
    langid = {english},
    }

RISeg: Robot Interactive Object Segmentation via Body Frame-Invariant Features

Howard Qian, Yangxiao Lu, Kejia Ren, Gaotian Wang, Ninad Khargonkar, Yu Xiang, Kaiyu Hang
ICRA 2024IEEE International Conference on Robotics and Automation (ICRA)
PDF Video
In order to successfully perform manipulation tasks in new environments, such as grasping, robots must be proficient in segmenting unseen objects from the background and/or other objects. Previous works perform unseen object instance segmentation (UOIS) by training deep neural networks on large-scale data to learn RGB/RGB-D feature embeddings, where cluttered environments often result in inaccurate segmentations. We build upon these methods and introduce a novel approach to correct inaccurate segmentation, such as under-segmentation, of static image-based UOIS masks by using robot interaction and a designed body frame-invariant feature. We demonstrate that the relative linear and rotational velocities of frames randomly attached to rigid bodies due to robot interactions can be used to identify objects and accumulate corrected object-level segmentation masks. By introducing motion to regions of segmentation uncertainty, we are able to drastically improve segmentation accuracy in an uncertainty-driven manner with minimal, non-disruptive interactions (ca. 2-3 per scene). We demonstrate the effectiveness of our proposed interactive perception pipeline in accurately segmenting cluttered scenes by achieving an average object segmentation accuracy rate of $80.7 \%$, an increase of $28.2 \%$ when compared with other state-of-the-art UOIS methods.
@article{qian_riseg_nodate,
    title = {{RISeg}: Robot Interactive Object Segmentation via Body Frame-Invariant Features},
    author = {Qian, Howard and Lu, Yangxiao and Ren, Kejia and Wang, Gaotian and Khargonkar, Ninad and Xiang, Yu and Hang, Kaiyu},
    langid = {english},
}

Kinematic Modeling and Control of a Soft Robotic Arm with Non-constant Curvature Deformation

Zhanchi Wang, Gaotian Wang, Xiaoping Chen, Nikolaos M Freris
ICRA 2024IEEE International Conference on Robotics and Automation (ICRA)
PDF
The passive compliance of soft robotic arms renders the development of accurate kinematic models and modelbased controllers challenging. The most widely used model in soft robotic kinematics assumes Piecewise Constant Curvature (PCC). However, PCC introduces errors when the robot is subject to external forces or even gravity. In this paper, we establish a three-dimensional (3D) kinematic representation of a soft robotic arm with pseudo universal and prismatic joints that are capable of capturing non-constant curvature deformations of the soft segments. We theoretically demonstrate that this constitutes a more general methodology than PCC. Simulations and experiments on the real robot attest to the superior modeling accuracy of our approach in 3D motions with unknown loads. The maximum position/rotation error of the proposed model is verified $6.7 \times / 4.6 \times$ lower than the PCC model considering gravity and external forces. Furthermore, we devise an inverse kinematic controller that is capable of positioning the tip, tracking trajectories, as well as performing interactive tasks in the 3D space.
@article{wang_kinematic_nodate,
        title = {Kinematic Modeling and Control of a Soft Robotic Arm with Non-constant Curvature Deformation},
        author = {Wang, Zhanchi and Wang, Gaotian and Chen, Xiaoping and Freris, Nikolaos},
        langid = {english},
    }

Dynamic modeling and Control of a Soft Robotic Arm Using a Piecewise Universal Joint Model

Zhanchi Wang, Gaotian Wang, Xiaoping Chen, Nikolaos M Freris
ROBIO 2023IEEE International Conference on Robotics and Biomimetics (ROBIO)
PDF Publisher Video
The Piecewise Constant Curvature (PCC) assumption is the most widely used in the modeling and control of soft robots. However, a limitation of PCC models lies in accurately describing the deformation of a soft robot when executing dynamic tasks such as operating under gravity or interacting with humans. This paper introduces a new methodology for dynamic modeling and control of a multi-segment soft arm in the 3D space where each segment undergoes non-constant curvature deformations. In this framework, the soft manipulator is modeled as a series of segments, with each one represented by two stretchable links connected by a universal joint. Furthermore, we devise and analyze a controller for motion control in the configuration space with unknown load. The controller is implemented on a four-segment soft robotic manipulator and validated in a range of dynamic trajectory tracking tasks.
@INPROCEEDINGS{10354732,
    author={Wang, Zhanchi and Wang, Gaotian and Chen, Xiaoping and Freris, Nikolaos M.},
    booktitle={2023 IEEE International Conference on Robotics and Biomimetics (ROBIO)}, 
    title={Dynamic modeling and Control of a Soft Robotic Arm Using a Piecewise Universal Joint Model}, 
    year={2023},
    volume={},
    number={},
    pages={1-6},
    keywords={Solid modeling;Three-dimensional displays;Deformation;Motion segmentation;Dynamics;Soft robotics;Aerospace electronics},
    doi={10.1109/ROBIO58561.2023.10354732}}

A Reinforcement Learning Method for Motion Control With Constraints on an HPN Arm

Yinghao Gan, Peijin Li, Hao Jiang, Gaotian Wang, Yusong Jin, Xiaoping Chen, Jianmin Ji
RA-L 2022IEEE Robotics and Automation Letters (RAL)
PDF Publisher
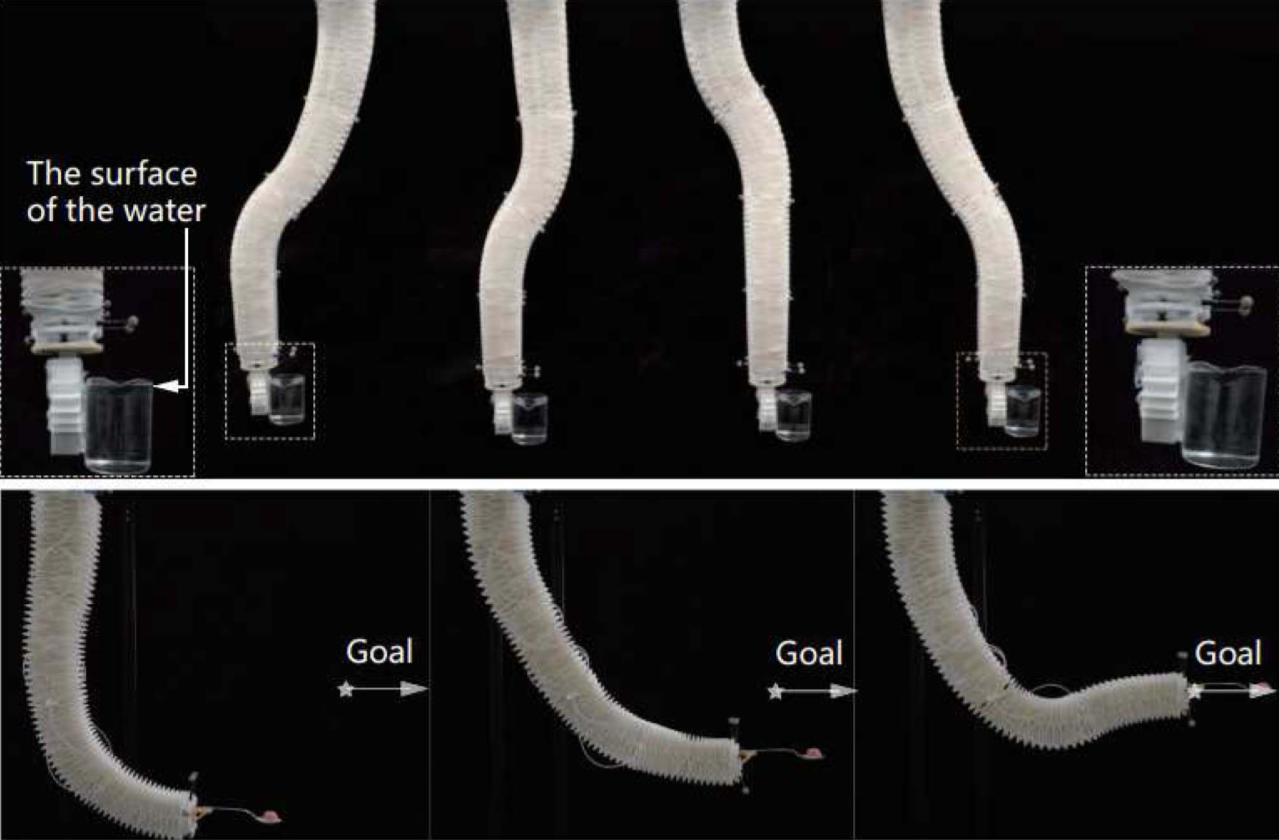
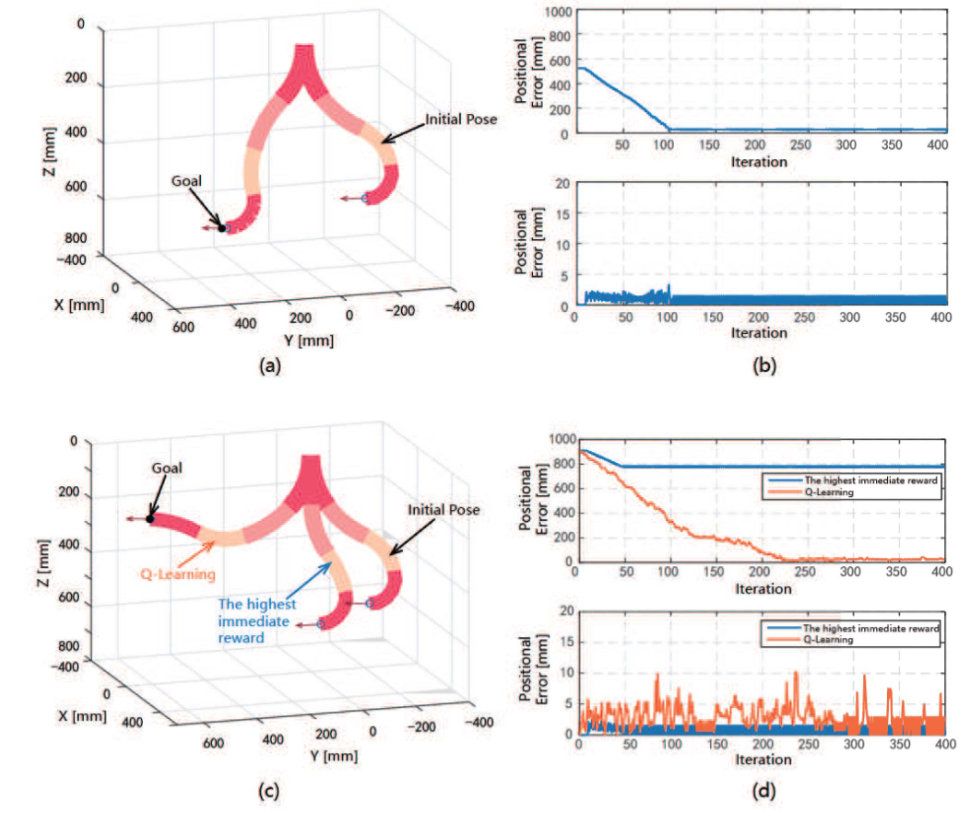
Soft robotic arms have shown great potential toward applications to human daily lives, which is mainly due to their infinite passive degrees of freedom and intrinsic safety. There are tasks in lives that require the motion of the robot to meet some certain pose constraints that have not been implemented through the soft arm, like delivering a glass of water. Because the workspace of the soft arm is affected by the loads or interaction, it is difficult to implement this task through the motion planning method. In this letter, we propose a Q-learning based approach to address the problem, directly achieving motion control with constraints under loads and interaction without planning. We first generate a controller for the soft arm based on Q-learning, which can operate the arm while satisfying the pose constraints when the arm is neither loaded nor interacted with the environment. Then, we introduce a process that adjusts corresponding Q values in the controller, which allows the controller to operate the arm with an unknown load or interaction while still satisfying the pose constraints. We implement the approach on our soft arm, i.e., the Honeycomb Pneumatic Network (HPN) Arm. The experiments show that the approach is effective, even when the arm reached an untrained situation or even beyond the workspace under the interaction.
@ARTICLE{9851517,
    author={Gan, Yinghao and Li, Peijin and Jiang, Hao and Wang, Gaotian and Jin, Yusong and Chen, Xiaoping and Ji, Jianmin},
    journal={IEEE Robotics and Automation Letters}, 
    title={A Reinforcement Learning Method for Motion Control With Constraints on an HPN Arm}, 
    year={2022},
    volume={7},
    number={4},
    pages={12006-12013},
    keywords={Motion control;Q-learning;Manipulators;Task analysis;Soft robotics;Load modeling;Data models;Machine learning for robot control;modeling;control;and learning for soft robots;soft robot applications},
    doi={10.1109/LRA.2022.3196789}}

A Q-learning Control Method for a Soft Robotic Arm Utilizing Training Data from a Rough Simulator

Peijin Li, Gaotian Wang, Hao Jiang, Yusong Jin, Yinghao Gan, Xiaoping Chen, Jianmin Ji
ROBIO 2021IEEE International Conference on Robotics and Biomimetics (ROBIO)
PDF Publisher
It is challenging to control a soft robot, where reinforcement learning methods have been applied with promising results. However, due to the poor sample efficiency, reinforcement learning methods require a large collection of training data, which limits their applications. In this paper, we propose a Q-learning controller for a physical soft robot, in which pre-trained models using data from a rough simulator are applied to improve the performance of the controller. We implement the method on our soft robot, i.e., Honeycomb Pneumatic Network (HPN) arm. The experiments show that the usage of pre-trained models can not only reduce the amount of the real-world training data, but also greatly improve its accuracy and convergence rate.
@INPROCEEDINGS{9739524,
    author={Li, Peijin and Wang, Gaotian and Jiang, Hao and Jin, Yusong and Gan, Yinghao and Chen, Xiaoping and Ji, Jianmin},
    booktitle={2021 IEEE International Conference on Robotics and Biomimetics (ROBIO)}, 
    title={A Q-learning Control Method for a Soft Robotic Arm Utilizing Training Data from a Rough Simulator}, 
    year={2021},
    volume={},
    number={},
    pages={839-845},
    keywords={Q-learning;Costs;Conferences;Biomimetics;Biological system modeling;Training data;Soft robotics},
    doi={10.1109/ROBIO54168.2021.9739524}}

Experience

Education

Rice University, Ph.D. in Computer ScienceHouston, TX · Advisor: Kaiyu Hang
2022 – Present
University of Science and Technology of China, B.S. in Optical EngineeringHefei, China · Advisor: Nikolaos M. Freris
Thesis: A Randomized Kinodynamic Planner for Soft Robots based on Piecewise Universal Joint Model
2018 – 2022

Industry

NVIDIA Seattle Robotics Lab, Research InternSeattle, WA · Long-horizon and robust agentic mobile robotic systems
May – Aug. 2026

Research

RobotΠ Lab, Graduate StudentRice University · Advisor: Kaiyu Hang
2022 – Present
AIoT Lab, Undergraduate ResearcherUSTC · Advisor: Nikolaos M. Freris
2021 – 2022
Reconfigurable Robotics Lab, Guest ResearcherEPFL, Lausanne · Supervisors: Fabio Zuliani, Jamie Paik
Apr – Sep. 2021
USTC Soft Robotics Lab, Undergraduate ResearcherUSTC · Advisors: Hao Jiang, Xiaoping Chen
2020 – 2021

Teaching

Teaching Assistant, Algorithmic RoboticsCOMP/ELEC/MECH 450/550, Rice University
Fall 2023
Teaching Assistant, Deep Learning for Vision & LanguageCOMP 646, Rice University
Spring 2023
In-lab Teaching Assistant, College Physics-Comprehensive ExperimentationUniversity of Science and Technology of China
Fall 2020–2022